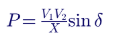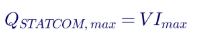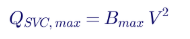
A Coordinated Electric System Interconnection Review—the utility’s deep-dive on technical and cost impacts of your project.

Challenge: Frequent false tripping using conventional electromechanical relays
Solution: SEL-487E integration with multi-terminal differential protection and dynamic inrush restraint
Result: 90% reduction in false trips, saving over $250,000 in downtime

The three operating regions you have to design to

Device Output vs voltage Response Best suited to Main limitations
Mechanically switched capacitor or reactor Proportional to voltage squared Seconds; discrete steps; limited switching operations per day Steady-state reactive supply, voltage profile, loss reduction No dynamic capability; step voltage change on switching; capability collapses when most needed
Static var compensator Capacitive branches proportional to voltage squared A few cycles; continuously controllable Continuous control where cost matters and deep voltage support is not the driver Square-law capability loss; harmonic filters are part of the plant and interact with the network
STATCOM Approximately proportional to voltage — constant current capability One to two cycles closed loop; converter response faster still Voltage stability margin, weak interconnections, fast disturbance recovery, flicker and unbalance compensation Higher capital cost; converter losses; adds a converter and its control dynamics to the network
Synchronous condenser Governed by machine capability and excitation Excitation response in the hundreds of milliseconds; inherent inertial response instantaneous System strength and inertia, short-circuit contribution, black start support Rotating plant with maintenance and losses; slower controlled response than a converter
STATCOM with energy storage Reactive as a STATCOM, plus real power within the storage rating As STATCOM for reactive; real power limited by storage Where a real power deficiency is part of the problem Cost and complexity of the storage; different failure and maintenance profile
Stage Keentel scope Outcome
Screening Series-compensation proximity, radial contingency review, UIF and short-circuit ratio screening, frequency scans Early identification of which SSO types apply
Detailed studies PSCAD/EMTDC EMT studies with vendor real-code models, impedance-based and frequency-scan analysis Clear evidence of stability margins or risk
Model quality EMT model review, benchmarking against positive-sequence models, model acceptance support Models that system operators accept
Mitigation Control retuning recommendations with vendors, SSDC and bypass logic requirements, protection and monitoring specifications Practical, coordinated solutions
Interconnection support SSR and SSO study reports for ISO and utility requirements, response to reviewer comments Fewer delays in the interconnection process

Resilience: designing CDUs to the facility Tier objective


Liquid cooling makes heat removal more critical, not less. Cold plates hold only seconds of thermal buffer. If TCS flow stops, processors throttle or shut down very quickly. Resilience design must therefore cover:


  • Pump redundancy: N+1 pumps at minimum, with automatic changeover.
  • CDU redundancy: N+1 CDUs on a common TCS header, or 2N CDUs serving A and B manifolds for fault-tolerant designs.
  • Power to CDUs: dual-corded CDUs fed from A and B sources, with pumps and controls on UPS power so coolant keeps flowing through a utility failure and generator start. This is the liquid-cooling equivalent of continuous cooling.
  • Facility water continuity: chilled water or condenser water must also continue, through thermal storage, UPS-backed pumps or a high enough FWS temperature that the TCS can coast on stored thermal mass for the transfer period.
  • Concurrent maintainability: isolation valves so any CDU, pump, filter or manifold section can be serviced without stopping the others.
  • Leak management: leak detection, drip trays, automatic isolation valves and procedures for fluid spills.


Electrical engineering considerations


CDUs and liquid-cooling plants are electrical loads with their own design requirements:


  • Pump motors and VFDs. Large CDUs use variable-frequency drives on their pump motors. These introduce harmonic current that must be included in the facility's harmonic study and IEEE 519 evaluation.
  • Critical mechanical load on UPS. Putting CDU pumps on UPS increases UPS and battery sizing. The mechanical UPS load must be included in redundancy and ride-through calculations.
  • Feeder and protection design. Dual feeds, automatic transfer, selective coordination and arc-flash labelling apply to CDU power distribution just as they do to IT power.
  • Generator transient response. CDU pumps restarting together after a transfer create motor inrush on the generators. Staged restarts and soft acceleration reduce the step load.
  • Load dynamics. AI training loads can swing rapidly between high and low power. Cooling controls must track those swings without temperature overshoot, and electrical systems must handle both the IT and the cooling load changes.


Commissioning a liquid-cooled data hall


  1. Flush and clean the TCS piping and manifolds to the specified cleanliness, using high-purity flush water.
  2. Fill and vent with the specified coolant, verifying glycol concentration and chemistry.
  3. Pressure test for leaks at design and test pressures, including quick-disconnect fittings.
  4. Verify sensors and controls: flow meters, temperature sensors, pressure transmitters, leak detection and BMS points.
  5. Load test with heat load banks connected through the cold-plate interfaces or rack manifolds, across the operating range.
  6. Prove the heat balance on both loops at several load steps, and the approach temperature against the design.
  7. Test failure scenarios: pump failure, CDU failure, power transfer to generator, valve failure and loss of facility water, confirming temperatures stay within the IT vendor's limits.


How Keentel Engineering helps


Keentel Engineering supports data center owners, developers and EPCs with the electrical engineering that liquid-cooled facilities depend on, and coordinates with the mechanical engineer of record and cooling vendors on the integrated design.
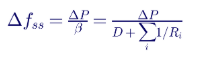
STATCOM Application and Voltage Stability: An Engineering Guide for US Transmission Systems

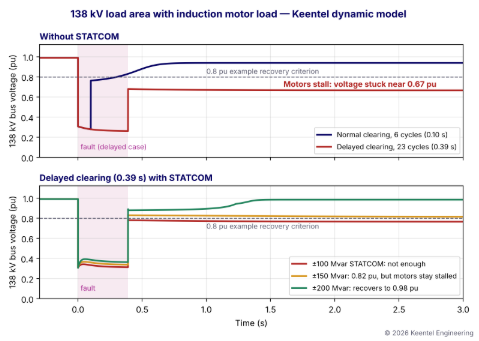
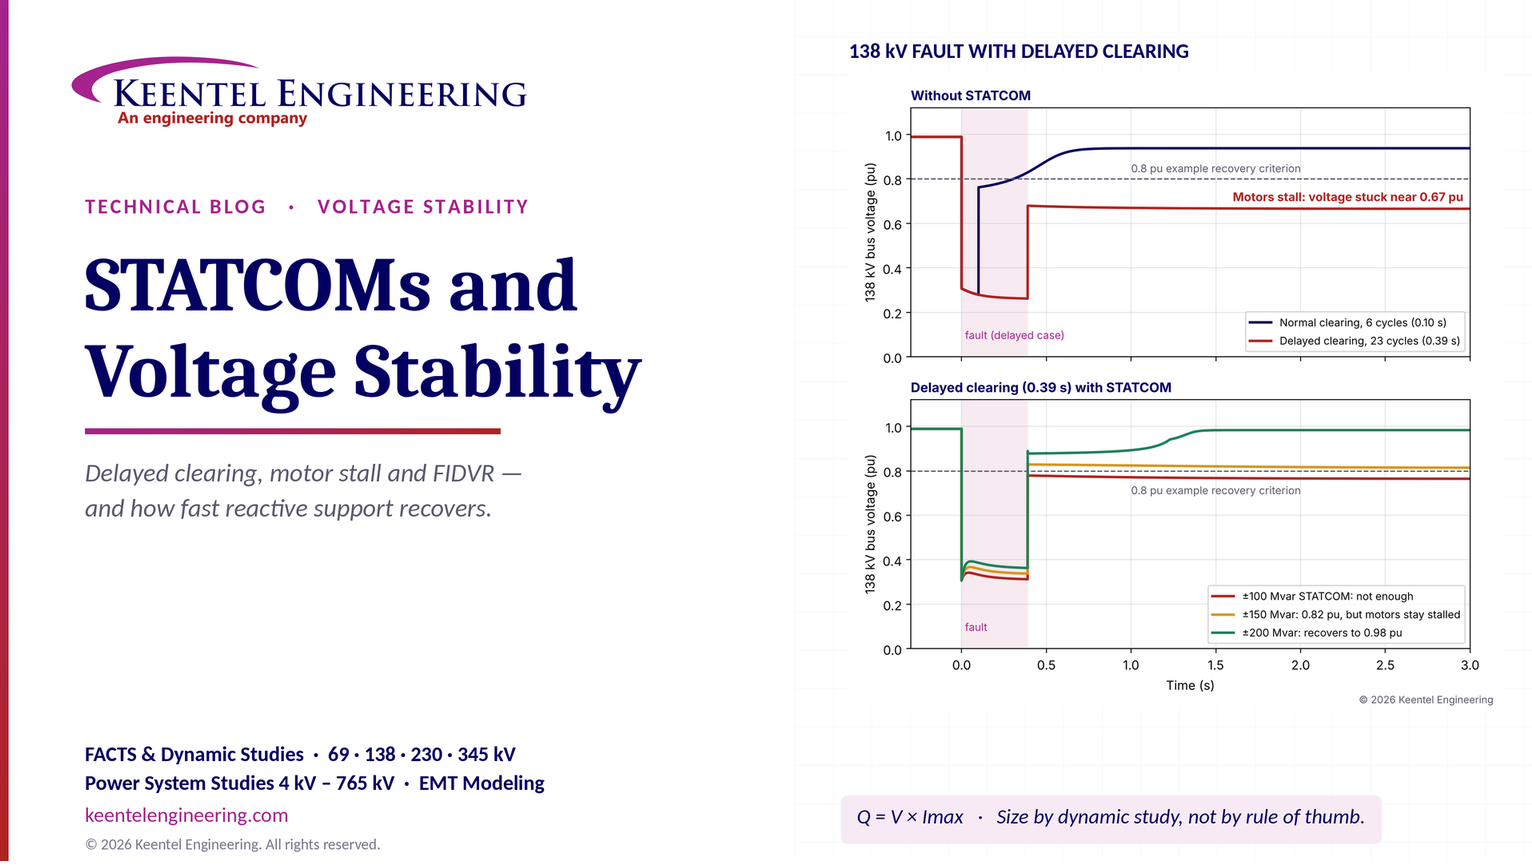
STATCOM voltage stability comparison showing 138 kV fault recovery and reactive power support.
Calendar icon. D

October 11, 2026 | Blog


Part A — STATCOMs and Voltage Stability at a Glance

A transmission fault depresses voltage across a wide area for as long as it lasts. When protection clears the fault quickly, voltage normally recovers within a fraction of a second. When clearing is delayed, by a stuck breaker or a protection failure, the voltage dip lasts longer, induction motors slow down and stall, and the stalled motors draw large reactive currents. Voltage can then stay depressed for seconds, oscillate or collapse altogether, even after the fault has been removed. A properly sized and tuned STATCOM (static synchronous compensator) injects fast reactive current during and after the fault, supporting voltage so motors can re-accelerate and the system can recover.


What Keentel's model shows


Keentel Engineering modeled a 138 kV load area serving 200 MW, half of it induction motor load with compressor-type constant torque characteristics, supplied through a transmission path that is weakened when the faulted line is removed.

Scenario Fault clearing Result at the 138 kV load bus
No STATCOM Normal, 6 cycles (0.10 s) Voltage recovers to about 0.94 pu
No STATCOM Delayed, 9 cycles (0.14 s) or longer Motors stall; voltage stays near 0.67 pu
±100 Mvar STATCOM Delayed, 23 cycles (0.39 s) Motors stall; voltage about 0.76 pu
±150 Mvar STATCOM Delayed, 23 cycles (0.39 s) Voltage held near 0.82 pu, but motors remain stalled
±200 Mvar STATCOM Delayed, 23 cycles (0.39 s) Motors re-accelerate; voltage recovers to about 0.98 pu

Figure 1. Voltage at the 138 kV load bus after a three-phase fault. Top: without a STATCOM, normal clearing recovers but delayed clearing leaves motors stalled. Bottom: with delayed clearing, only the ±200 Mvar STATCOM restores normal voltage.


Key lessons


  • Clearing time matters as much as Mvar. In this model, the critical clearing time without a STATCOM is about 8 cycles. Faster protection alone would prevent the stall.
  • Rating must come from studies. A STATCOM that is too small can hold voltage above a screening threshold while motors remain stalled, hiding the problem.
  • Voltage alone is not proof of recovery. Motor speed, current and reactive demand must also return to normal.
  • Short-circuit strength, load composition, control settings and disturbance severity all determine the required rating.

A STATCOM is not just an Mvar rating. It is a fast voltage-control system whose size, response and settings must match the system's strength, its load and its worst credible disturbance.


Part B — STATCOM Application and Voltage Stability: An Engineering Guide for US Transmission Systems

Voltage stability problems are among the most consequential events a transmission planner can face. They can turn a single fault into a wide-area outage, and they often develop in summer, when air-conditioning load is high and generation is far from load. Fast reactive power devices — STATCOMs, static var compensators (SVCs) and synchronous condensers — are key tools for preventing them. This guide explains why voltage collapses after faults, how a STATCOM works, how to size and tune it using US planning practice, and how to verify its performance with studies.


Voltage stability: the basics


Voltage stability is the ability of a power system to maintain acceptable voltages at all buses after a disturbance. Under IEEE and CIGRE definitions, it is commonly divided into:


  • Short-term (transient) voltage stability: within a few seconds, driven by fast load dynamics such as induction motors and by inverter-based resources.
  • Long-term voltage stability: over tens of seconds to minutes, driven by transformer tap changers, thermostatically controlled loads and generator reactive limits.


The event in this article is short-term voltage instability, often called fault-induced delayed voltage recovery (FIDVR) when it results from motor stalling after a transmission fault.


Why power transfer limits voltage


Power transfer over a transmission path is limited by its reactance and the voltages at each end:

As transfer approaches the limit, small increases in load require large increases in reactive power, and voltage becomes very sensitive. PV (power-voltage) and QV (reactive power-voltage) curves quantify that margin.


Voltage sensitivity and short-circuit strength


At a bus with short-circuit capacity Ssc, the steady-state voltage change caused by injecting reactive power Q is approximately:

where:

At a 138 kV bus with Ssc = 2,500 MVA, a 100 Mvar injection raises voltage by about 4%. At a weak bus with Ssc = 600 MVA, the same injection raises voltage by about 17%. The same STATCOM therefore has very different effects at different locations.


Why voltage collapses after a delayed-clearing fault


Induction motors, especially single-phase residential air-conditioner compressors and three-phase commercial and industrial motors, are the main driver of FIDVR.


  1. During the fault, voltage at the load falls to a fraction of normal. Motor electrical torque falls with the square of voltage:

  2. Motors decelerate, because their mechanical load torque, nearly constant for compressors, now           exceeds electrical torque.

  3. If the fault lasts too long, motor slip passes the point of maximum torque and motors stall. A stalled       motor draws locked-rotor current, typically 5 to 6 times rated, at a low power factor.

  4. After the fault clears, the stalled motors' large reactive demand keeps voltage depressed. The                transmission path is also weaker because the faulted element has been removed.

   5.Voltage stays low until motor thermal protection trips the motors, typically after several seconds or          longer, or until the system collapses.


Clearing time in cycles


Clearing times are usually expressed in 60 Hz cycles:

Clearing condition Typical total clearing time
Normal clearing, 138 kV to 345 kV 3 to 6 cycles (0.05 to 0.10 s)
Breaker failure clearing (stuck breaker) Roughly 10 to 15 cycles (0.17 to 0.25 s)
Remote backup, zone 2 or time-delayed clearing 20 cycles or more (0.33 s or longer)

A 0.39 s (23-cycle) clearing time, as in the delayed case modeled here, is characteristic of remote backup or time-delayed clearing rather than normal protection. Under NERC TPL-001, planners must study delayed-clearing events caused by stuck breakers and protection system failures.


How a STATCOM works


A STATCOM is a voltage-source converter (VSC), using IGBTs or similar devices, connected to the transmission system through a coupling transformer. By controlling the magnitude of its output voltage relative to system voltage, it injects capacitive or inductive reactive current:


  • Converter voltage above system voltage: the STATCOM supplies reactive power (capacitive).
  • Converter voltage below system voltage: the STATCOM absorbs reactive power (inductive).


Modern modular multilevel converter (MMC) STATCOMs respond within one to two cycles, produce very low harmonics and can be built from about ±25 Mvar to several hundred Mvar.


STATCOM versus SVC at low voltage


A key advantage of a STATCOM is that it is current-limited rather than admittance-limited. At reduced voltage, its maximum reactive output falls linearly with voltage:

An SVC behaves like a controlled susceptance, so its maximum output falls with the square of voltage:

Bus voltage STATCOM output (rated 100 Mvar) SVC output (rated 100 Mvar)
1.0 pu 100 Mvar 100 Mvar
0.8 pu 80 Mvar 64 Mvar
0.5 pu 50 Mvar 25 Mvar
0.3 pu 30 Mvar 9 Mvar

During deep voltage dips, the STATCOM delivers substantially more reactive support. Some STATCOMs also offer a short-term overload rating for a few seconds, which can be valuable for fault recovery.


STATCOM, SVC and synchronous condenser compared

Feature STATCOM SVC Synchronous condenser
Response time 1 to 2 cycles 2 to 3 cycles Inherent and immediate
Output at low voltage Proportional to V Proportional to V² High short-term output; contributes fault current
Short-circuit contribution Limited to converter current None Significant, increases system strength
Inertia None None Yes
Footprint Compact Larger (reactors, capacitors, filters) Large rotating machine and auxiliaries
Typical application Dynamic voltage support, FIDVR, IBR integration Dynamic voltage support, load compensation System strength, inertia and voltage support

Sizing a STATCOM


Steady-state screening: QV curves


A QV curve plots the reactive power needed at a bus to hold each voltage. The minimum of the curve shows the reactive margin. Planners run QV curves for critical contingencies to estimate the reactive support needed to maintain voltage margin.


Dynamic sizing: time-domain simulation


FIDVR cannot be sized from steady-state analysis. It requires time-domain simulation with dynamic load models. In Keentel's model, the steady-state analysis would suggest a small device, but dynamic simulation showed:

STATCOM rating Maximum reactive output during recovery Result
±100 Mvar ≈ 78 Mvar (current-limited at reduced voltage) Motors stall
±150 Mvar ≈ 125 Mvar Voltage held near 0.82 pu; motors stay stalled
±175 Mvar ≈ 165 Mvar Slow recovery, about 2.1 s to reach 90% of pre-fault voltage
±200 Mvar ≈ 188 Mvar Recovery to 90% in about 0.57 s after clearing; final voltage 0.98 pu

The ±150 Mvar case is the most instructive. Voltage stays above an 0.8 pu screening threshold, so a study that checks only voltage might accept it. But the motors never re-accelerate, the STATCOM is pinned at its current limit, and the system is one more disturbance away from collapse.


The load model is critical


Results depend heavily on load representation. US planning models increasingly use the WECC composite load model (CMPLDW and its successors), which represents single-phase air-conditioner motors with stall behavior, three-phase motors of different types, power electronic loads and distributed energy resources. A constant impedance or constant current load model can completely hide FIDVR risk.


Control design and tuning


A STATCOM's performance depends as much on its controls as on its rating:


  • Voltage regulation with slope (droop): typically 1 to 5% on the STATCOM rating, to share reactive power with other devices and avoid hunting.
  • Response speed: fast enough to support voltage during recovery, but coordinated with nearby controls to avoid oscillation.
  • Low-voltage behavior: whether the STATCOM blocks, limits or stays in full current output during deep faults.
  • Overload strategy: use of short-term overload capability during recovery.
  • Coordination with switched shunts: fast dynamic capacity should be kept available by switching capacitor banks and reactors for steady-state needs, often called dynamic reserve management.
  • Weak-grid interactions: in areas with many inverter-based resources, STATCOM and plant controller gains must be tuned with EMT studies to avoid control interactions and oscillations.


US planning criteria

Requirement Application to STATCOM projects
NERC TPL-001 Planning events including single contingencies, stuck breakers and protection system failures, with dynamic stability and voltage performance requirements
Regional and utility transient voltage criteria Post-fault voltage recovery and minimum voltage limits defined by planning coordinators and utilities
NERC PRC-010 Undervoltage load shedding programs, an alternative or complement to dynamic reactive support
NERC PRC-024 and PRC-029 Ride-through of generators and inverter-based resources during voltage disturbances
NERC MOD-032 and MOD-033 Modeling data and validation of dynamic models against actual events
IEEE Std 1052 Guide for specifying transmission STATCOM systems
IEEE Std 1031 Guide for specifying transmission static var compensators
IEEE Std 519 Harmonic performance at the point of connection

Other ways to prevent FIDVR


A STATCOM is one of several mitigation options, and the best solution often combines them:


  1. Faster fault clearing: upgraded protection, communication-assisted schemes and breaker failure improvements can eliminate delayed clearing.
  2. Undervoltage load shedding: sheds load in a controlled way to restore voltage.
  3. Synchronous condensers: provide dynamic reactive power, inertia and system strength.
  4. SVCs: lower cost per Mvar for some applications but weaker at low voltage.
  5. Transmission reinforcement: new lines or transformers increase system strength.
  6. Load-side measures: air-conditioner compressor protection and standards that reduce stall risk.
  7. Inverter-based resources: solar, wind and battery plants with dynamic reactive capability under IEEE 2800-2022.


Studying a STATCOM project


  1. Event analysis: use PMU, DFR and SCADA data from actual events to validate system and load models.
  2. Base case and contingency screening: steady-state and QV analysis for TPL-001 contingencies.
  3. Dynamic simulation: PSS®E, PSLF or PowerFactory simulations with composite load models and delayed-clearing events.
  4. Siting and sizing: compare locations by sensitivity and short-circuit strength; size for the worst events.
  5. EMT studies: PSCAD studies of control interactions, harmonics, weak-grid behavior and protection.
  6. Specification: rating, overload, response time, losses, harmonics, availability and redundancy under IEEE 1052.
  7. Commissioning and model validation: staged tests and validation of the dynamic model against measured performance.


How Keentel Engineering helps


Keentel Engineering provides transmission planning, dynamic stability and FACTS engineering for utilities, transmission developers, independent power producers and large industrial customers, from 4 kV to 765 kV.

Stage Keentel scope Outcome
Event analysis Review of PMU, DFR and SCADA data; reproduction of actual events in dynamic models A clear explanation of what happened and why
Voltage stability studies PV and QV analysis, TPL-001 dynamic studies, FIDVR assessment with composite load models Identified risks and quantified reactive needs
FACTS sizing and siting STATCOM, SVC and synchronous condenser comparison, location and rating studies The right device at the right location
EMT and control studies PSCAD control interaction, weak-grid and harmonic studies Stable, well-tuned controls
Specification and owner's engineer IEEE 1052-based technical specifications, bid evaluation and design review Equipment that meets the performance requirement
Substation design and protection 69 kV to 345 kV substation design, protection upgrades and communication-assisted schemes Faster clearing and reliable integration
NERC compliance TPL-001, PRC-010, PRC-024, PRC-029, MOD-032 and MOD-033 support Documented, audit-ready compliance

Why clients choose Keentel Engineering


  • Planning and design under one roof: the engineers who study the problem also design the substation and protection solution.
  • Model-driven decisions: dynamic and EMT studies replace rules of thumb, so equipment is neither oversized nor undersized.
  • NERC and utility experience: practical knowledge of planning criteria, compliance and utility processes.
  • Licensed professional engineering: a Florida-registered firm with offices in Tampa, Austin, Sacramento and Baltimore, supporting projects nationwide.
  • Technology-neutral advice: STATCOMs, SVCs, synchronous condensers, protection upgrades or transmission — whichever solves the problem best.


Facing voltage recovery problems, FIDVR risk or a FACTS decision? Talk to Keentel Engineering at (813) 389-7871, contact@keentelengineering.com, or book a 15-minute scoping call at calendly.com/keentel-engineering/15min.


Part C — Case Studies

The following are illustrative scenarios based on conditions typical of US transmission systems. They show how Keentel Engineering approaches voltage stability and FACTS problems; site details are generalised and figures are rounded.


Case Study 1 — 138 kV summer load pocket: FIDVR after a delayed-clearing event


Situation. A utility serving a fast-growing suburban area with heavy residential air-conditioning load experiences a 138 kV fault with delayed clearing. Voltage in the area stays below 0.75 pu for several seconds before load trips on motor protection.


Analysis. Keentel reproduces the event in a dynamic model using PMU data and the composite load model, then studies TPL-001 stuck-breaker and protection-failure events. Simulations show stall-driven FIDVR for clearing times above about 9 cycles, and QV analysis alone underestimates the reactive need by more than half.


Engineered solution. Keentel recommends two coordinated measures: protection upgrades at two substations to reduce worst-case clearing time, and a ±200 Mvar STATCOM at the area's central 138 kV substation, with dynamic reserve management of existing capacitor banks.


Outcome. All studied contingencies meet the utility's transient voltage criteria, and the combined solution costs less than the transmission reinforcement originally considered.


Case Study 2 — 230 kV renewable area: STATCOM and weak-grid control interaction


Situation. A transmission owner plans a STATCOM at a 230 kV substation surrounded by large solar and wind plants, where short-circuit ratios are low.


Analysis. Positive-sequence studies show adequate voltage support, but Keentel's PSCAD studies reveal a poorly damped oscillation between the STATCOM voltage control and nearby plant controllers under weak N-1 conditions.


Engineered solution. Keentel retunes the STATCOM voltage regulator gain and slope, coordinates reactive priorities with the inverter-based plants, and recommends a synchronous condenser study for further system strength.


Outcome. The STATCOM and plants operate stably across all studied conditions, and the specification includes EMT model and validation requirements.


Case Study 3 — 69 kV industrial plant: motor starting and flicker


Situation. A manufacturing plant served at 69 kV adds large motors and a resistance welding line. Motor starts cause voltage dips that trip sensitive equipment, and the utility reports flicker at the point of common coupling.


Analysis. Keentel's motor starting and flicker studies show voltage dips of more than 12% during the largest motor starts and flicker levels above utility planning limits under IEEE 1453.


Engineered solution. A ±30 Mvar STATCOM at the plant's 13.8 kV bus provides fast voltage support during motor starts and compensates the fluctuating welding load, combined with soft-starting on the largest motors.


Outcome. Motor start dips fall below 5%, flicker meets utility limits, and nuisance equipment trips stop.


Part D — Technical FAQ: STATCOMs and Voltage Stability

A static synchronous compensator is a voltage-source converter connected to the grid through a transformer. It injects or absorbs reactive current very quickly to regulate voltage.

Voltage stability is the ability of the power system to maintain acceptable voltages at all buses after a disturbance. It can be short-term, driven by motors and inverters, or long-term, driven by tap changers and generator limits.

Fault-induced delayed voltage recovery is a condition in which voltage remains low for several seconds after a fault has been cleared, typically because induction motors, especially air-conditioner compressors, stall during the fault.

Motor electrical torque falls with the square of voltage. During a deep voltage dip, torque falls below the mechanical load torque, and the motor decelerates. If the dip lasts long enough, the motor stalls and draws high reactive current.

The longer a fault lasts, the more motors decelerate and stall. A stuck breaker or protection failure can extend clearing time from about 5 cycles to 15 cycles or more, which can be the difference between recovery and collapse.

A STATCOM is a current-limited voltage source, so its maximum output falls linearly with voltage. An SVC is a controlled susceptance, so its output falls with the square of voltage. At low voltage, a STATCOM provides more support.

Modern STATCOMs typically respond within one to two cycles, fast enough to support voltage during fault recovery.

Initial screening uses QV curves, but sizing for FIDVR requires time-domain simulation with dynamic load models and the worst delayed-clearing events. Location, short-circuit strength and control settings also determine the required rating.

A STATCOM can hold voltage above a threshold while motors remain stalled and the STATCOM is at its limit. Recovery should be confirmed by motor speed, current and reactive demand returning to normal, as well as voltage.

It is a dynamic load model widely used in US planning that represents single-phase air-conditioner motors, three-phase motors, power electronic loads and distributed resources. It is essential for studying FIDVR.

The voltage change from a reactive injection is roughly the injected Mvar divided by the short-circuit MVA. A STATCOM has more effect at a weak bus, but control interactions are also more likely there.

NERC TPL-001 defines the planning events and performance requirements. PRC-010 covers undervoltage load shedding. MOD-032 and MOD-033 cover model data and validation. PRC-024 and PRC-029 address generator and inverter ride-through.

IEEE Std 1052 provides guidance for specifying transmission STATCOM systems, IEEE Std 1031 for SVCs, and IEEE Std 519 for harmonic performance.

When the system also needs short-circuit strength and inertia, such as in areas with very high inverter-based generation or after synchronous generator retirements. Synchronous condensers provide all three, while STATCOMs provide fast reactive power only.

Not always. Faster clearing reduces motor stalling at the source and is often the most cost-effective first step. A STATCOM complements protection improvements when delayed clearing cannot be eliminated or when steady-state and dynamic voltage support are both needed.

It is the practice of using mechanically switched capacitors and reactors for steady-state voltage control so that the STATCOM's fast dynamic capacity remains available for disturbances.

Positive-sequence models do not fully represent fast converter controls, weak-grid interactions or harmonics. PSCAD EMT studies verify control stability, especially near inverter-based resources and other FACTS devices.

Some STATCOMs can deliver more than their continuous rating for a few seconds. This can be valuable for fault recovery but must be specified and verified with the manufacturer.

Yes. Distribution-level STATCOMs support voltage during large motor starts, compensate fluctuating loads such as welders and arc furnaces, and reduce flicker and voltage dips.

By comparing simulated and measured responses during commissioning tests and actual disturbances, using PMU and DFR data, and updating the planning model as required under MOD-033.


References and Further Reading

Links were current at publication (October 2026).


  • NERC Reliability Standard TPL-001, Transmission System Planning Performance Requirements. North American Electric Reliability Corporation.
  • NERC Reliability Standards PRC-010, PRC-024, PRC-029, MOD-032 and MOD-033. North American Electric Reliability Corporation.
  • NERC, Fault-Induced Delayed Voltage Recovery (FIDVR) technical reference documents and Reliability Guidelines on load modeling. North American Electric Reliability Corporation.
  • IEEE Std 1052, Guide for Specification of Transmission Static Synchronous Compensator (STATCOM) Systems. IEEE.
  • IEEE Std 1031, Guide for the Functional Specification of Transmission Static Var Compensators. IEEE.
  • IEEE/CIGRE Joint Task Force, Definition and Classification of Power System Stability. IEEE Transactions on Power Systems.
  • P. Kundur, Power System Stability and Control. McGraw-Hill.

Disclaimer

This article is general technical information for educational purposes. It is not engineering advice for any specific project and does not create a professional relationship. The frequency results are from Keentel Engineering's simplified center-of-inertia model with illustrative parameters, not field data; actual system performance depends on detailed generator, governor, inverter, load and protection models. UFLS settings, reserve products and requirements differ by region and change over time. Project designs must follow current standards, ISO/RTO and transmission provider requirements and project-specific engineering analysis, sealed by a licensed professional engineer where required.

Case studies are illustrative scenarios based on typical project conditions, not records of specific client projects. Figures are rounded and indicative.


NERC, FERC, ERCOT, IEEE, PSS®E, PSLF, PSCAD™ and other names are the property of their respective owners. Keentel Engineering is not affiliated with or endorsed by these organisations or any software or equipment vendor.

Office Address Phone
Head Office — Tampa 400 N Ashley Dr STE #2600, Tampa FL 33602 (813) 389-7871
Austin 5900 Balcones Drive STE 100, Austin TX 78731 (512) 591-0752
Sacramento 1401 21st St Ste R, Sacramento CA 95811 (916) 913-4524
Baltimore 306 W Redwood St STE 200, Baltimore MD 21201 (410) 225-2181

contact@keentelengineering.com  ·  keentelengineering.com  ·  calendly.com/keentel-engineering/15min


State of Florida — Registry No. 36853, KEENTEL LLC, DBA: KEENTEL ENGINEERING

Copyright 1995–2026 Keentel Engineering. All Rights Reserved.


A smiling man with glasses and a beard wearing a blue blazer stands in front of server racks in a data center.

About the Author:

Sandip "Sonny" R. Patel, P.E.

IEEE Senior Member · Founder & CEO, Keentel Engineering

In 1995, Sonny Patel earned his Electrical Engineering degree from the University of Illinois. But degrees don't build legacies — action does.

For three decades, he has worked the power industry from every side of the table: 16 years as a utility engineer at Exelon/Commonwealth Edison; generation leadership across hydroelectric, industrial steam turbine, and a 9 GW renewable fleet; NERC Regional Entity Senior Compliance Engineer and Audit Team Lead, auditing some of the nation's largest utilities; and testing and commissioning lead on equipment up to 765 kV — the very top of the North American grid.Utility. Generator. Regulator. Consultant. Few engineers have seen all four seats. Fewer still have sat in them.

His experience spans nuclear, hydro, conventional generation, renewables, oil and gas, mining — and today's data centers, where he is authoring a three-book series on data center design. He is a Licensed Professional Engineer in six states and a Licensed Electrical Contractor in Florida (Unlimited EC) — he doesn't just design the work; he's qualified to stand behind its execution.Today, as Founder and CEO of Keentel Engineering, Sonny leads a nationwide team of engineers delivering substation design, power system studies, NERC compliance, and commissioning — done right, coast to coast.Three decades. Every side of the table. One standard: accountable engineering.

Four workers in safety vests and helmets stand with arms crossed near wind turbines.

Let's Discuss Your Project

Let's book a call to discuss your electrical engineering project that we can help you with.

Man in a blazer and open shirt, looking at the camera, against a blurred background.

About the Author:

Sandip "Sonny" R. Patel, P.E.

IEEE Senior Member · Founder & CEO, Keentel Engineering

In 1995, Sonny Patel earned his Electrical Engineering degree from the University of Illinois. But degrees don't build legacies — action does.

For three decades, he has worked the power industry from every side of the table: 16 years as a utility engineer at Exelon/Commonwealth Edison; generation leadership across hydroelectric, industrial steam turbine, and a 9 GW renewable fleet; NERC Regional Entity Senior Compliance Engineer and Audit Team Lead, auditing some of the nation's largest utilities; and testing and commissioning lead on equipment up to 765 kV — the very top of the North American grid.

Utility. Generator. Regulator. Consultant. Few engineers have seen all four seats. Fewer still have sat in them.

His experience spans nuclear, hydro, conventional generation, renewables, oil and gas, mining — and today's data centers, where he is authoring a three-book series on data center design. He is a Licensed Professional Engineer in six states and a Licensed Electrical Contractor in Florida (Unlimited EC) — he doesn't just design the work; he's qualified to stand behind its execution.

Today, as Founder and CEO of Keentel Engineering, Sonny leads a nationwide team of engineers delivering substation design, power system studies, NERC compliance, and commissioning — done right, coast to coast.Three decades. Every side of the table. One standard: accountable engineering.

Leave a Comment

Related Posts

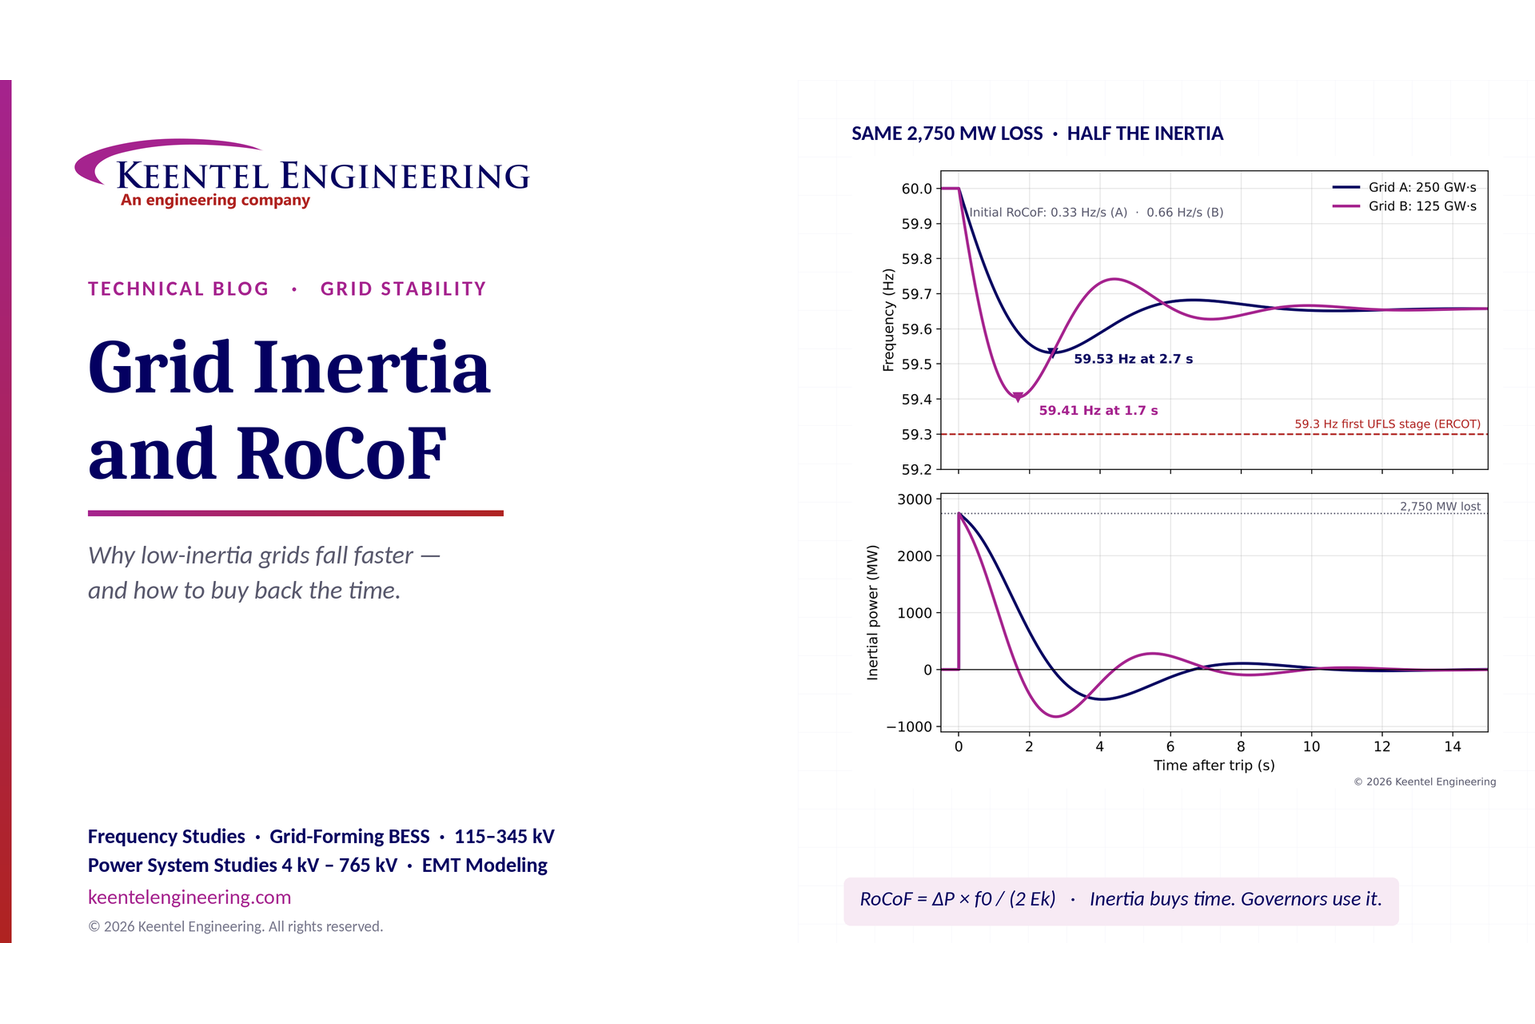
Grid inertia and RoCoF comparison showing frequency response, inertial power, and grid stability aft
By SANDIP R PATEL • October 11, 2026
Explore grid inertia, RoCoF and frequency response, with swing equation calculations, frequency nadir analysis and US power system simulation examples.
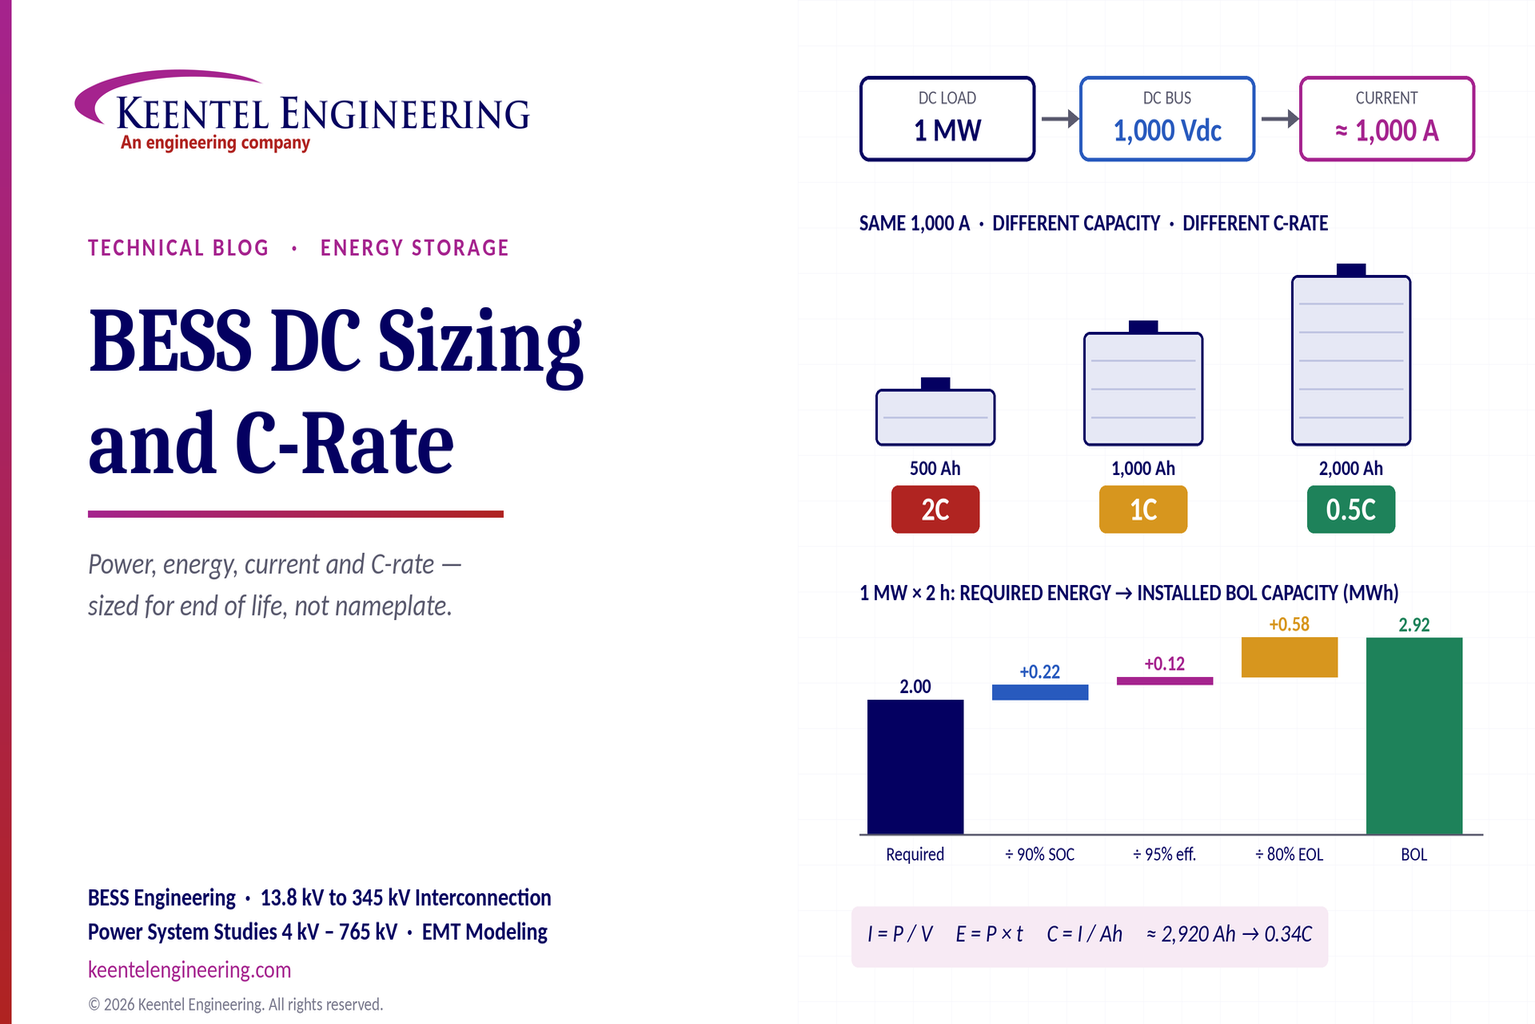
BESS DC sizing and C-rate comparison showing battery capacity, discharge rates, and energy storage s
By SANDIP R PATEL • October 10, 2026
Learn BESS DC sizing with power, energy, current and C-rate calculations, battery losses, degradation and a 100 MW/400 MWh utility-scale example.
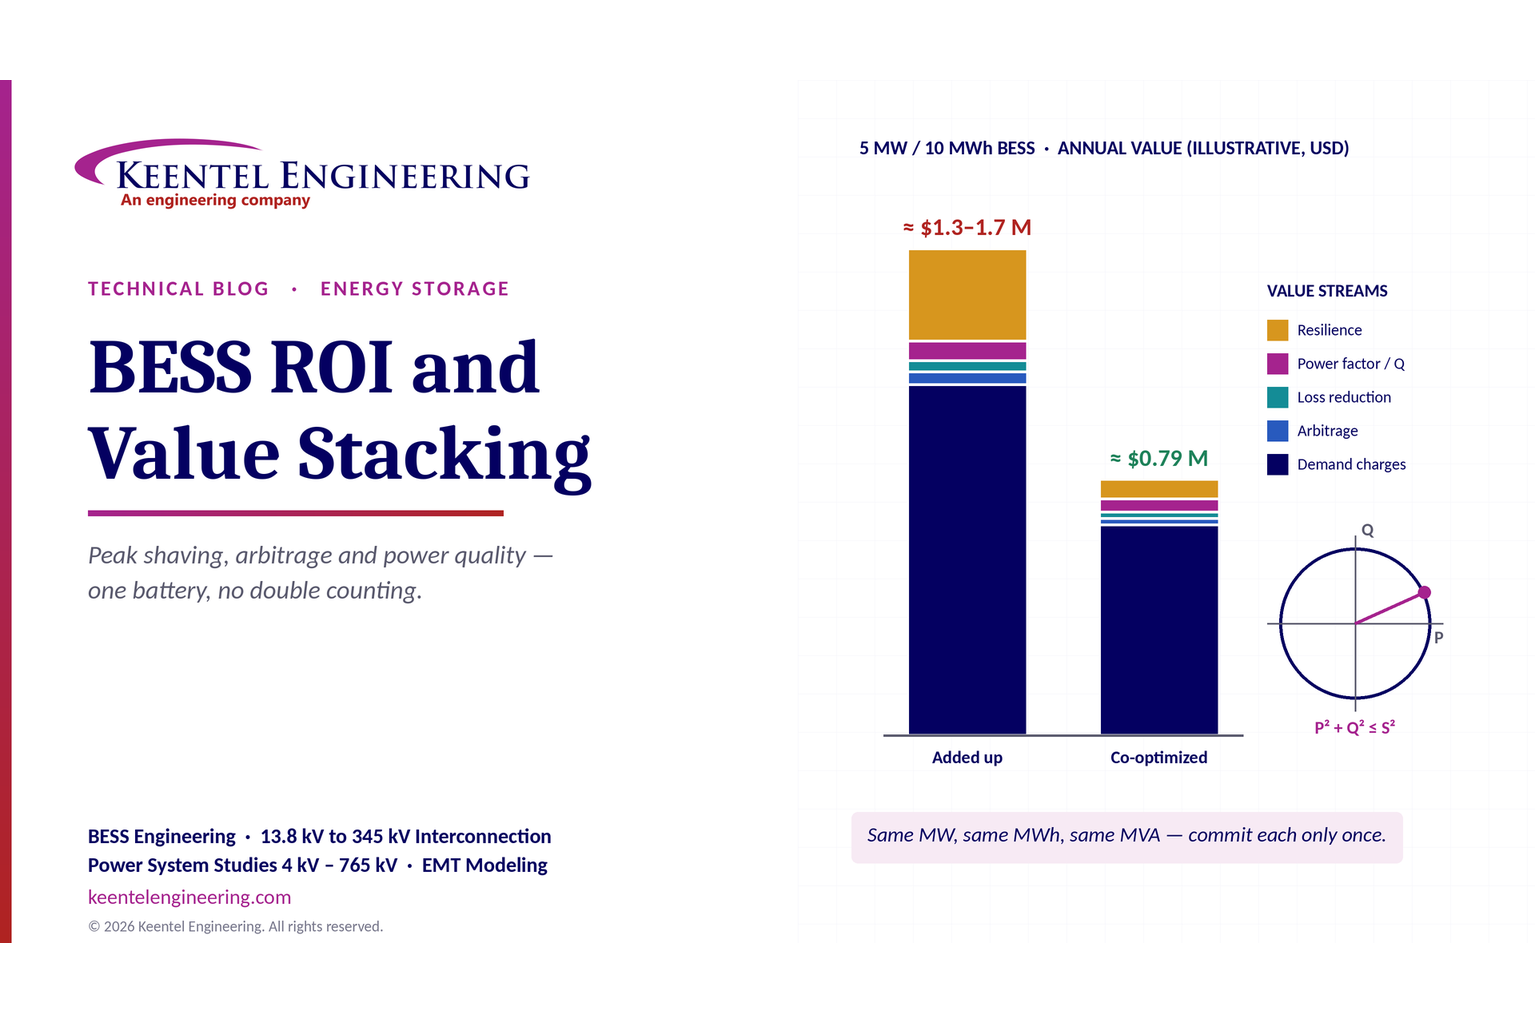
BESS ROI and value stacking comparison showing battery energy storage revenue streams, peak shaving,
By SANDIP R PATEL • October 10, 2026
Learn how BESS ROI is calculated using peak shaving, energy arbitrage, power quality and battery storage economics, with a practical 5 MW/10 MWh example.
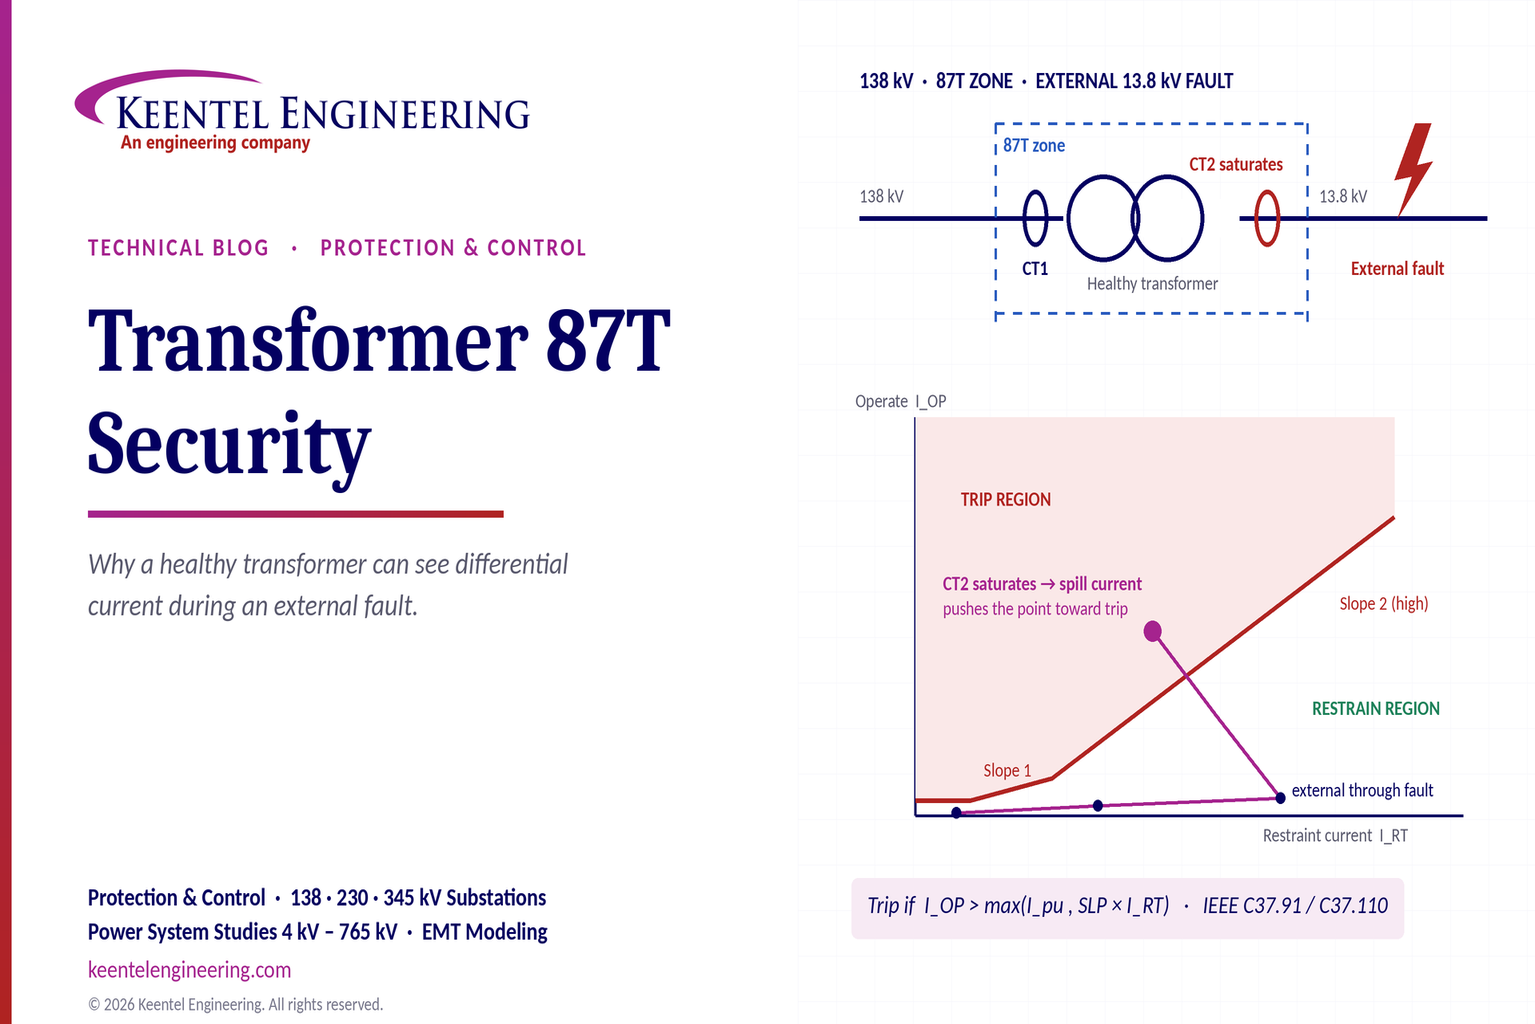
Transformer 87T differential protection diagram showing CT saturation, external faults, and relay tr
By SANDIP R PATEL • October 10, 2026
Learn why transformer differential relays detect current during external faults, how CT saturation causes spill current, and how secure 87T protection prevents trips.
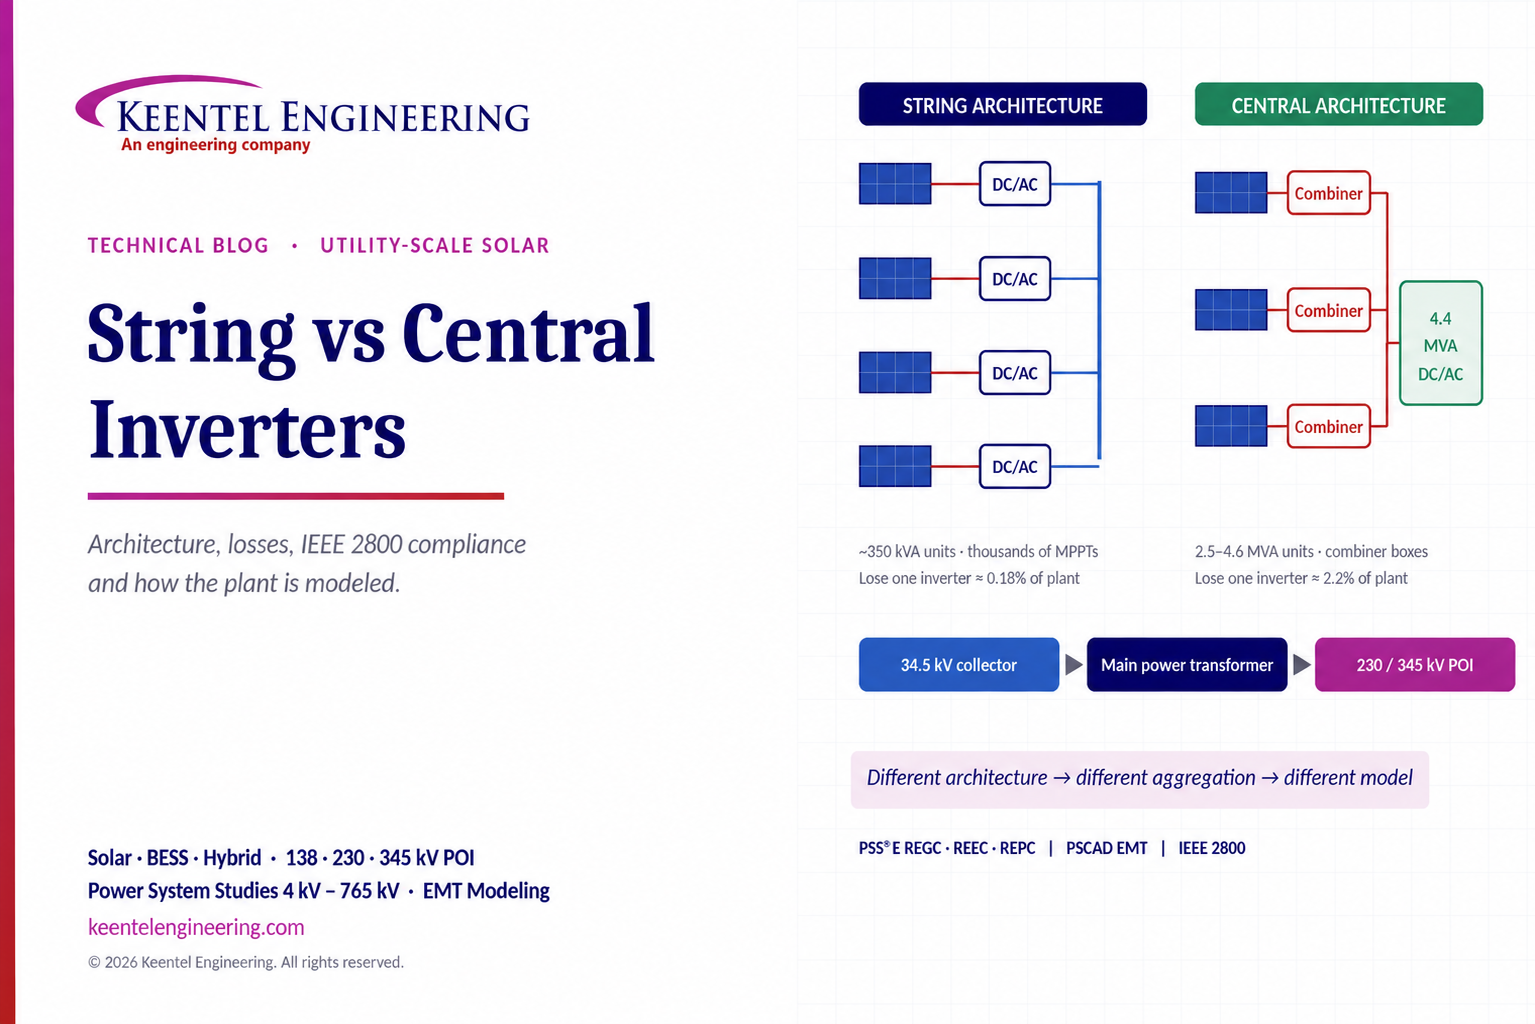
SEO Alt Text: String vs central solar inverters comparison showing PV system architecture, DC/AC con
By SANDIP R PATEL • October 10, 2026
Compare string vs central inverters for utility-scale solar, including efficiency, maintenance, grid compliance, reactive power and interconnection studies.
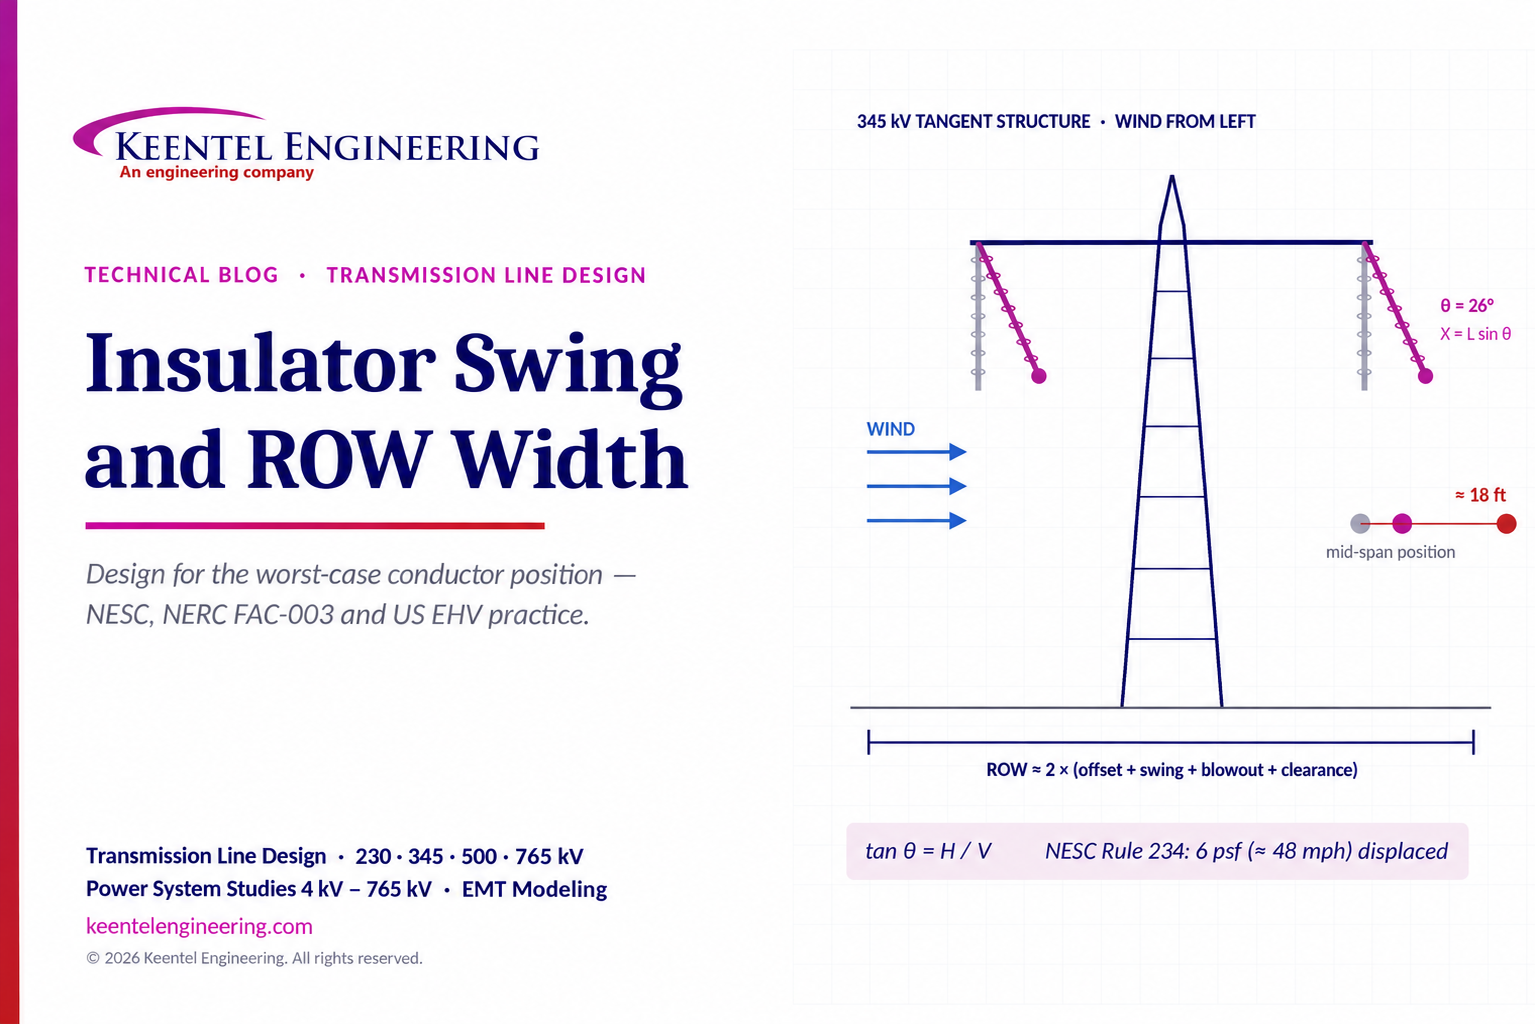
345 kV transmission line insulator swing angle and ROW width diagram.
By SANDIP R PATEL • October 9, 2026
Learn how insulator swing angle and conductor blowout affect transmission line ROW width, with NESC clearances, NERC FAC-003 guidance, and a 345 kV example. Copy
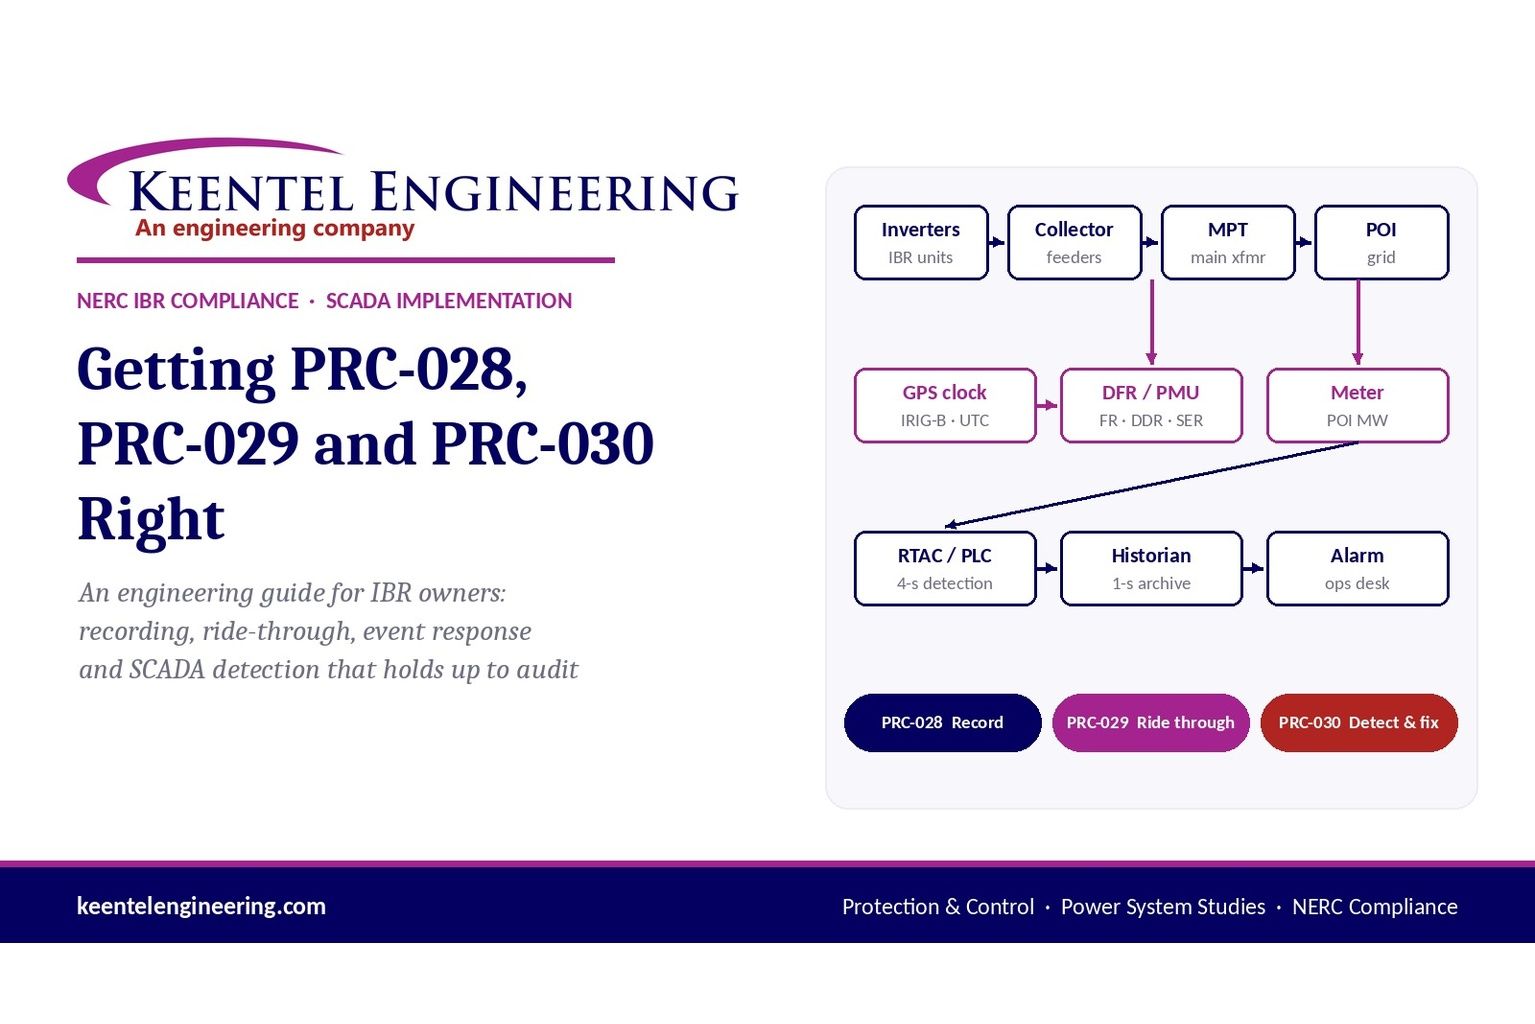
PRC-028 PRC-029 and PRC-030 NERC IBR compliance guide
By SANDIP R PATEL • October 3, 2026
Engineering guide to PRC-028 disturbance recording, PRC-029 ride-through and PRC-030 event detection for inverter-based resources.
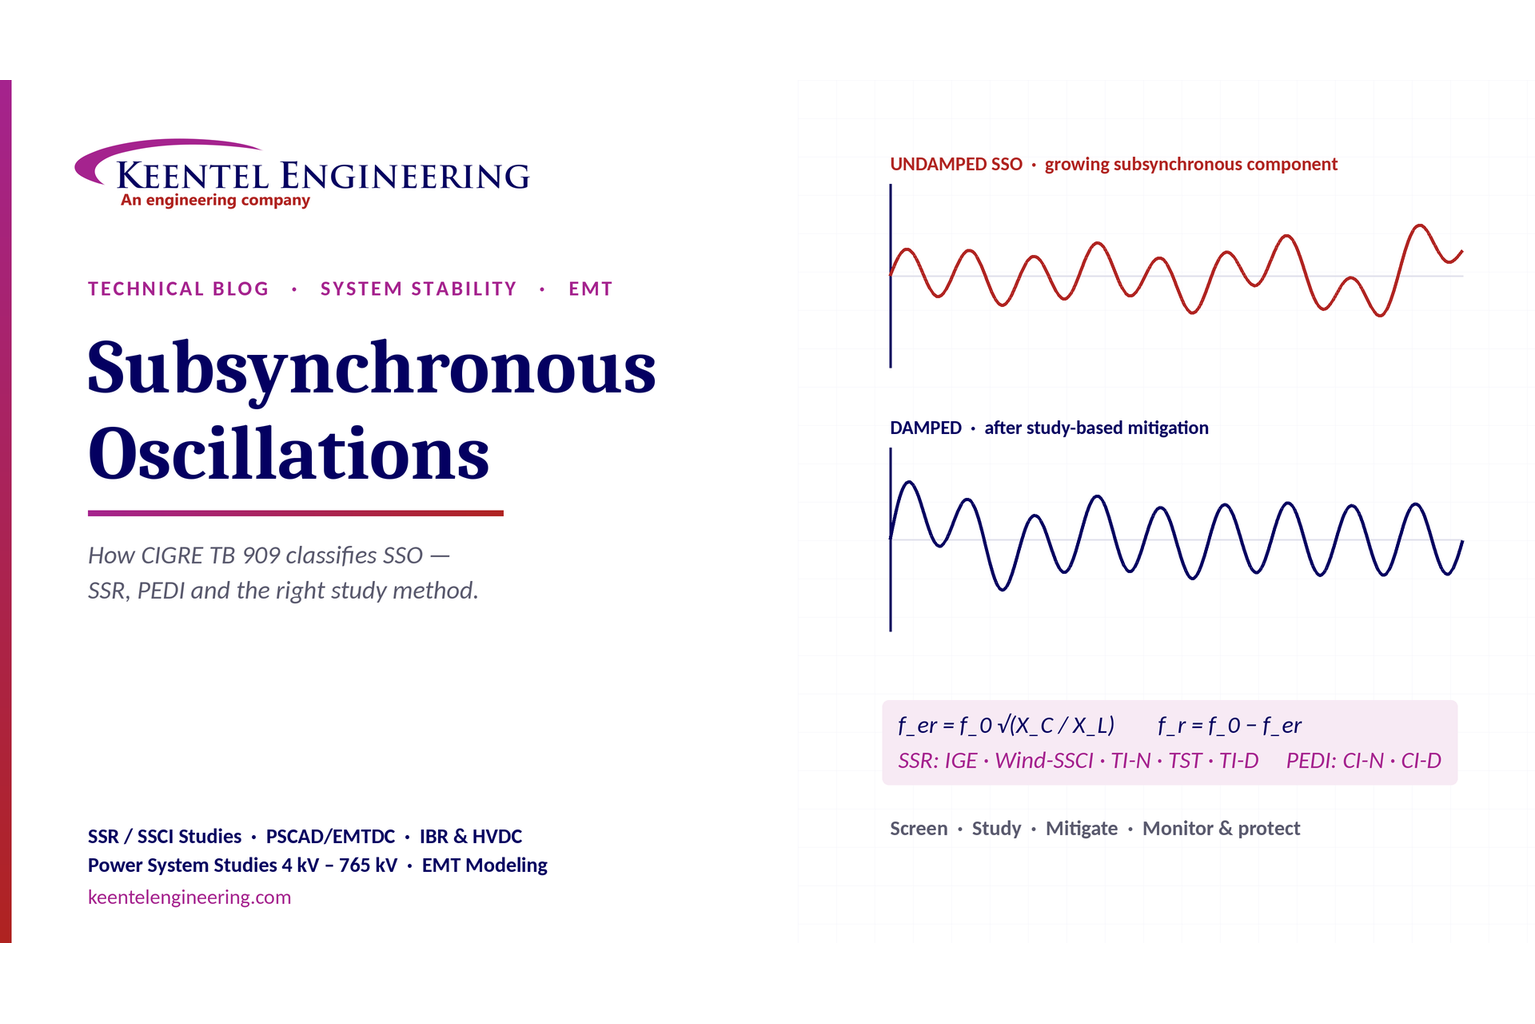
Keentel Engineering graphic showing damped and undamped subsynchronous oscillations.
By SANDIP R PATEL • October 3, 2026
A practical guide to SSO classification, SSR, PEDI, Wind-SSCI, EMT analysis, mitigation and protection based on CIGRE TB 909.
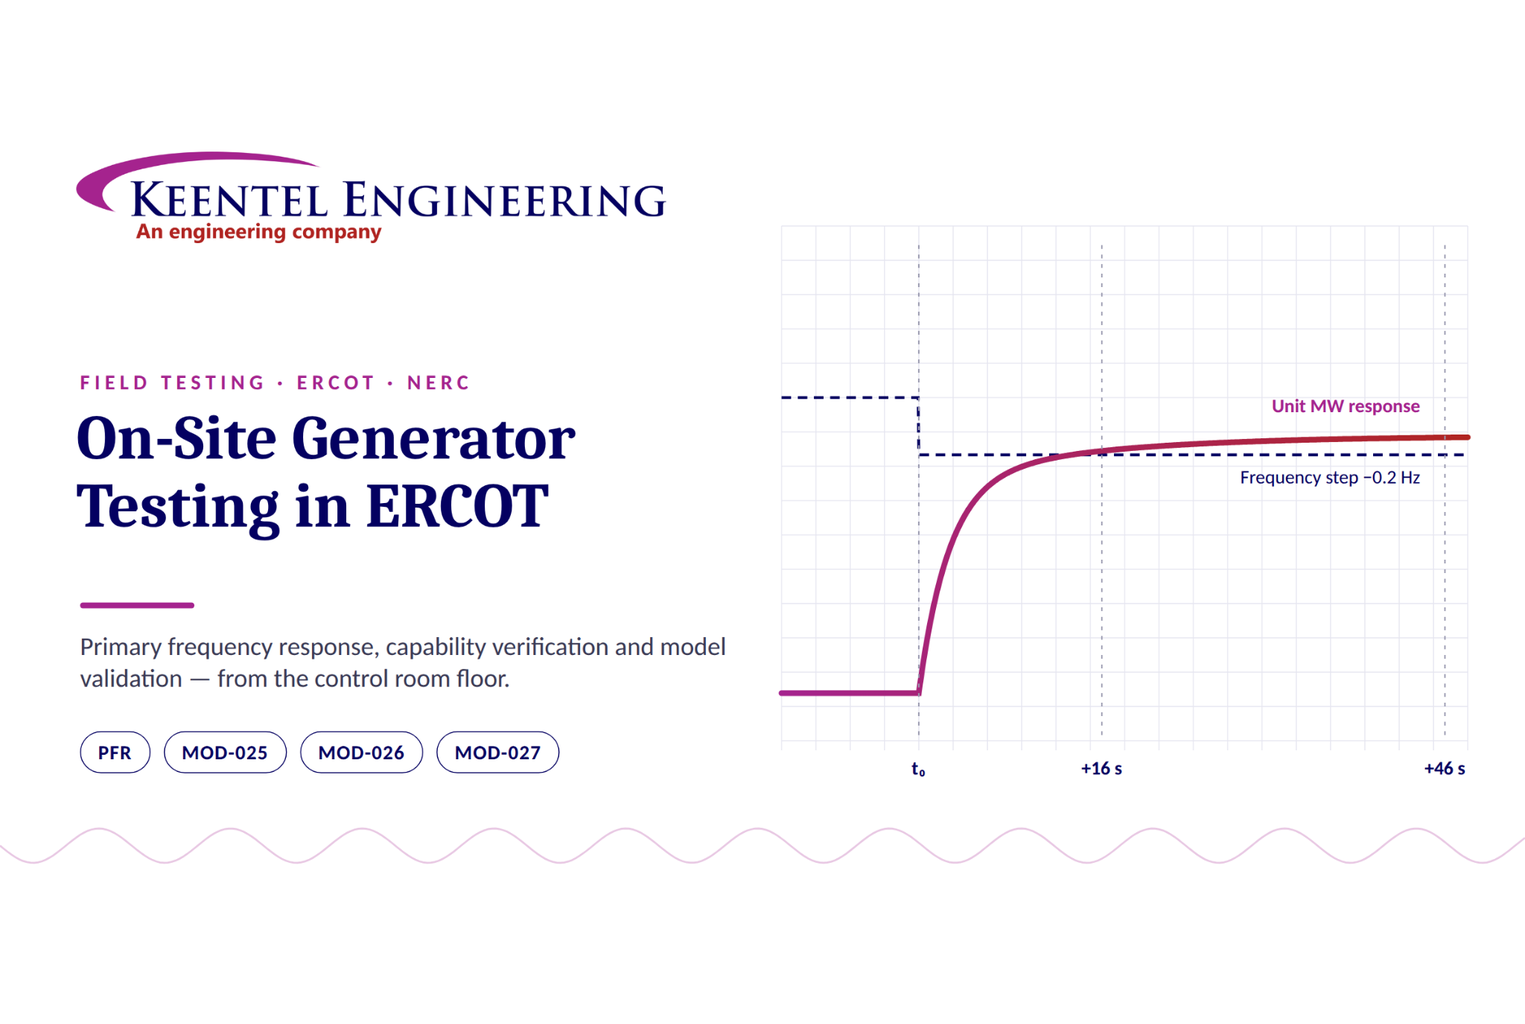
On-site generator testing in ERCOT
By SANDIP R PATEL • October 3, 2026
Learn ERCOT generator testing for PFR, MOD-025 and MOD-026/027, including staged tests, capability verification, dynamic models and field testing.